

Research
Active Perception
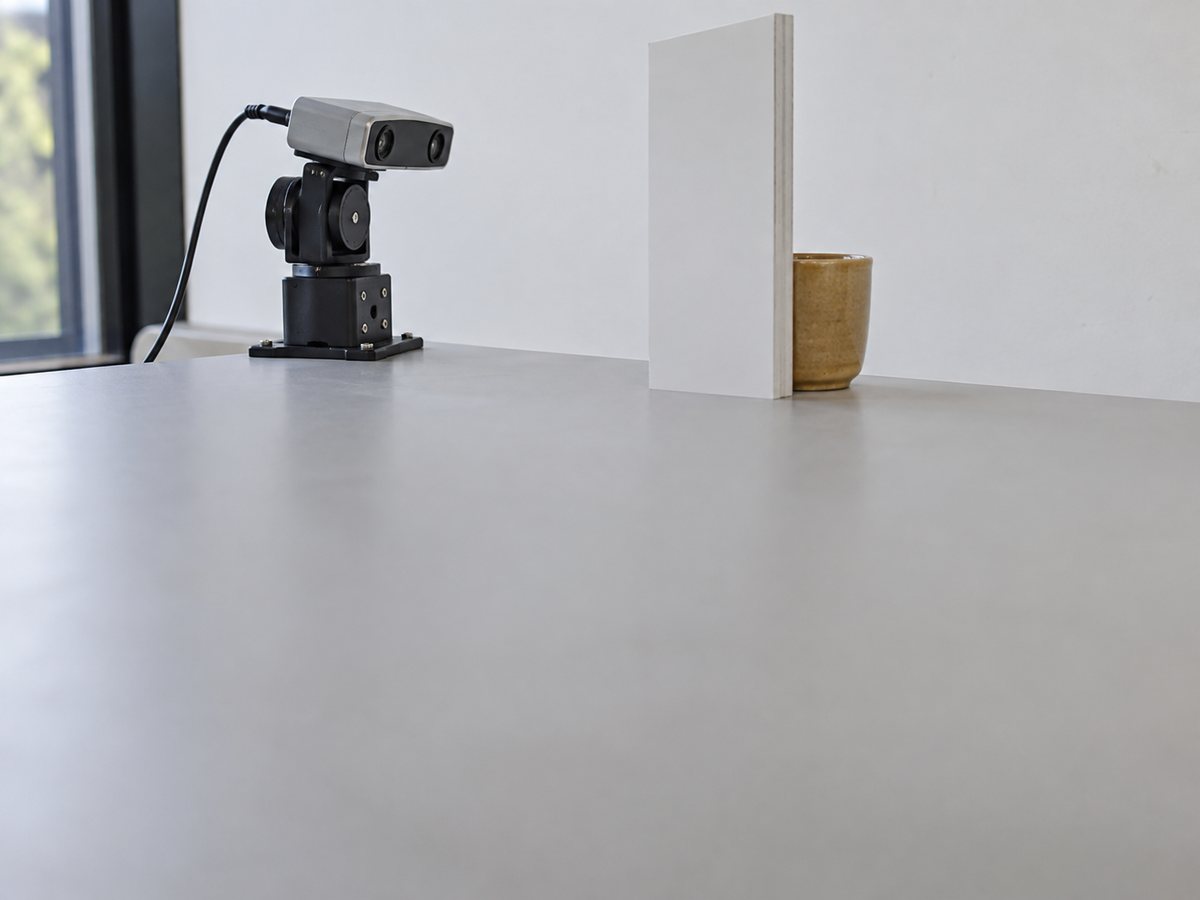
Deciding where to look and when to look again — resolving ambiguity through deliberate interaction rather than passive observation.
Perception is not passive. We study how robots should move sensors and bodies to gather the information a task actually requires — deciding where to look, when to look again, and how to resolve ambiguity through deliberate interaction with the environment.
This turns perception into a decision problem: the robot must estimate what it does not yet know, and judge whether finding out is worth the time it costs.