

Research
Hybrid Imitation & Reinforcement Learning
Demonstrations give a strong start, reinforcement refines it — with an emphasis on sample efficiency and sim-to-real transfer.
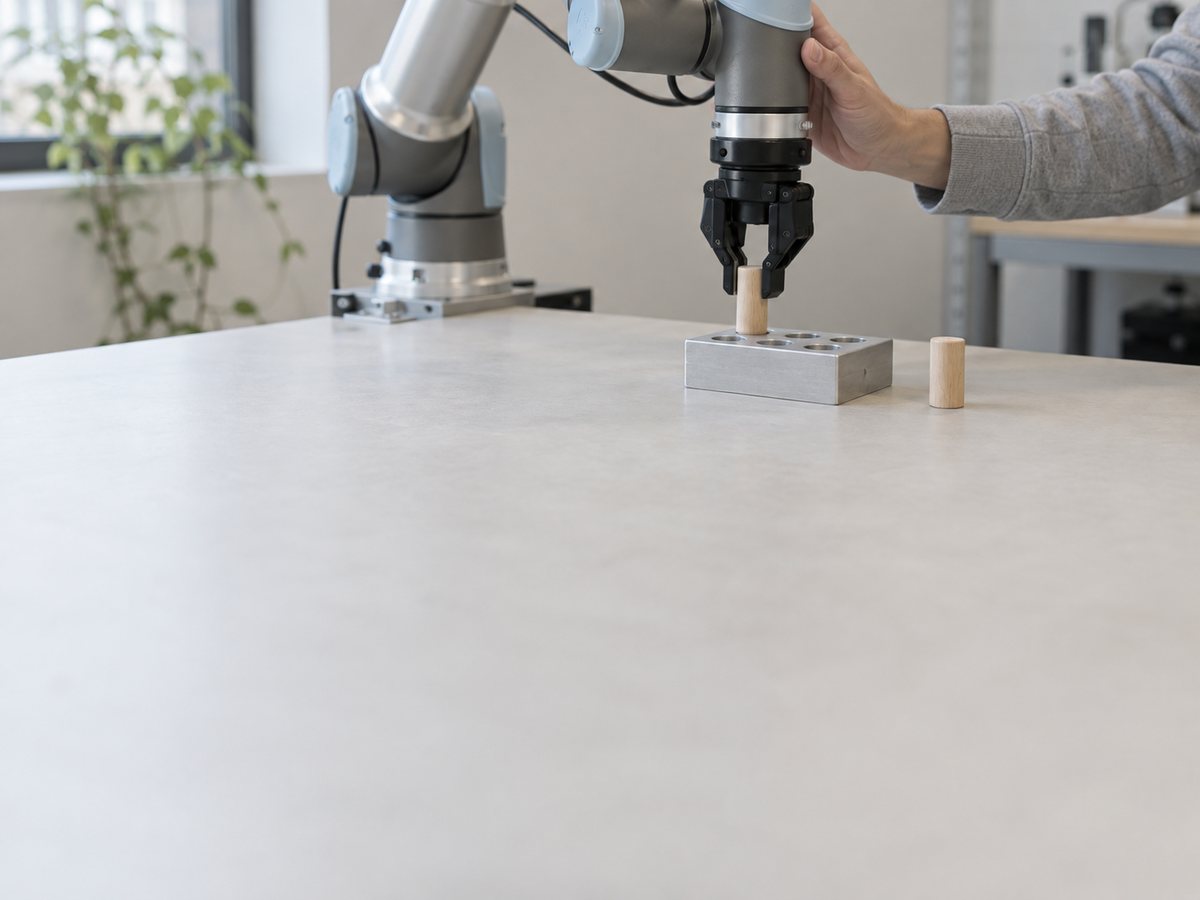
Demonstrations give a strong starting point; reinforcement learning refines it. We combine the two so that robots learn quickly from human data and then improve through their own experience, with an emphasis on sample efficiency and on transferring policies from simulation to physical hardware.
The interesting difficulty is knowing when to stop trusting the demonstration — human data is a prior, not a ceiling.