

Research
Robotic World Models
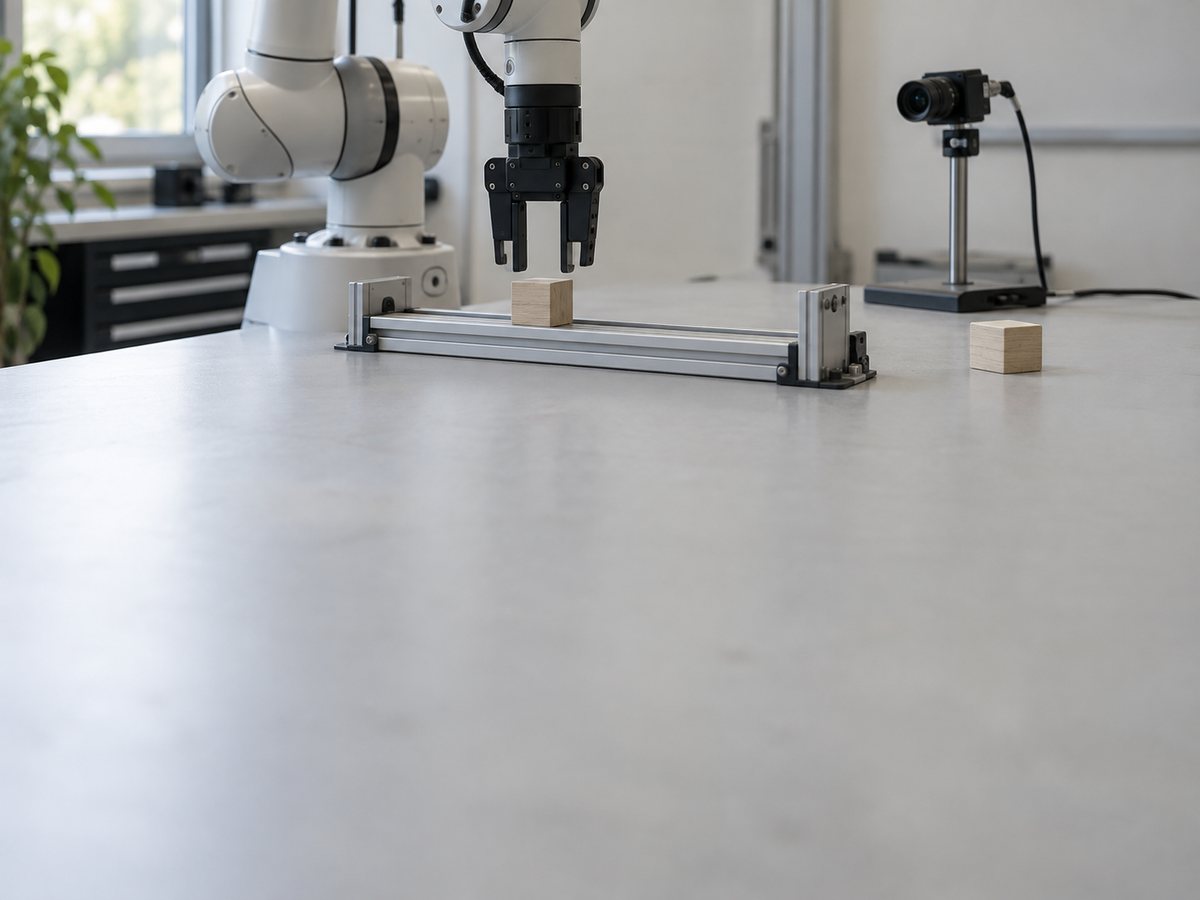
Learned models of environment dynamics, letting a robot anticipate the consequences of an action before committing to it.
Robots that act over long horizons need some model of how the world responds to what they do. We learn predictive models of environment dynamics that let a robot anticipate the consequences of an action before committing to it, and use them for planning, evaluation, and sample-efficient training.
A model that is merely accurate on average is not enough — what matters is whether it is reliable about the situations where a mistake is expensive.